
Executive Overview
For generations, the transition from open-water cruising to a tight marina slip has been one of the most high-stakes, anxiety-inducing rituals in boating. Whether navigating a bustling harbor under crosswinds, managing a heavy single-screw cruiser without thrusters, or dealing with the unpredictable currents of a crowded basin, close-quarters maneuvering remains a friction point for skippers of all experience levels. Historically, mastering this maritime rite of passage required years of muscle memory, spatial awareness, and a healthy tolerance for scraped gelcoat.
Enter Simrad Yachting’s AutoCaptain—a breakthrough autonomous docking system that fundamentally changes how boats interact with their environments. By merging a factory-integrated array of 360-degree stereo cameras, machine vision, machine learning algorithms, and Mercury Marine’s advanced Joystick Piloting propulsion, AutoCaptain takes the guesswork out of close-quarters handling.
What sets AutoCaptain apart in a rapidly evolving market of marine electronics is its origin. Unlike aftermarket add-ons or disparate sensor packages retrofitted onto existing hulls, AutoCaptain is the product of comprehensive vertical integration. Developed under the Brunswick Corporation umbrella—which owns both Navico Group (Simrad’s parent company) and Mercury Marine—it represents the first time a major marine conglomerate has built an autonomous close-quarters ecosystem from the steering wheel and propulsion out to the multifunction displays and processors.
Currently debuting exclusively aboard the high-end Boston Whaler 405 Conquest, AutoCaptain introduces Level 2-plus autonomy to the water, offering a hands-off, helmside-monitored solution to docking, undocking, and short-range spatial management. As the marine industry moves toward software-defined vessel operations, AutoCaptain stands as a watershed moment for how recreational boating approaches safety, accessibility, and automation.
Detailed Chronology: From Late-Night Docking Nightmares to Smart Autonomy
To understand the engineering leap that AutoCaptain represents, it helps to look backward. For decades, close-quarters maneuvering has been an exercise in human stress management. Consider the classic scenario: returning to a dimly lit marina after a long day on the water, battling an outgoing tide, with tired crew members and a heavy vessel responding sluggishly to traditional wheel-and-throttle inputs. The resulting "dockmares" have cost boat owners countless dollars in fiberglass repairs and bruised egos.
While sensor-based docking aids have trickled into the marine market over the past several years, they have traditionally suffered from integration hurdles. Separate radar systems, independent bow thrusters, third-party cameras, and disparate chartplotters often required complex marine electronics configurations, leaving room for communication latency and frustrating troubleshooting loops when hardware failed.
Simrad’s development of AutoCaptain bypassed these patchwork solutions by treating the boat as a unified, interconnected cyber-physical system. The genesis of the project relied on the close corporate alignment between Navico Group and Mercury Marine. Engineers recognized that true autonomy could not be achieved simply by slapping cameras onto a hardtop; it required deep-level command of variable-RPM thrust, gear shifts, and vector steering.
The timeline of AutoCaptain’s rollout is purposefully deliberate. Rather than releasing a fragmented aftermarket product requiring complex dealer installations, Brunswick Corporation elected a factory-exclusive strategy. The system makes its commercial debut on the Boston Whaler 405 Conquest, a premium midsize cabin boat equipped with factory-installed hardtop camera arrays and multi-outboard Mercury propulsion. According to company executives, this closed-ecosystem approach is the foundation upon which all future maritime autonomy will be built, ensuring seamless compatibility and a unified service experience for the end-user.
Supporting Context & Metrics: Under the Hood of AutoCaptain
AutoCaptain’s impressive capability is driven by an intricate architecture of hardware, software, and artificial intelligence. To evaluate how the system operates in real-world conditions, it is necessary to examine its core technical specifications and operational layers.
Hardware Architecture
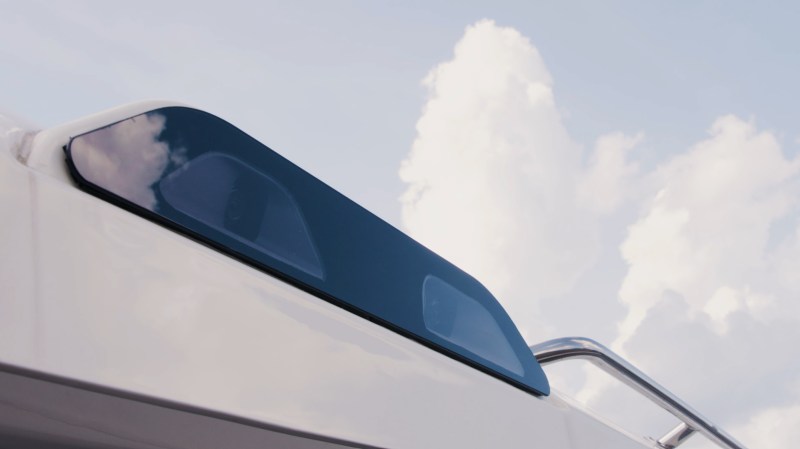
- Visual Array: Six factory-installed stereo cameras mounted strategically within the hardtop, delivering comprehensive 360-degree visibility around the vessel.
- Processing Core: A dedicated high-performance black-box processor running advanced machine vision and route-planning algorithms.
- User Interface: At least one Simrad NSO 4 or NSS 4 multifunction display running the proprietary AutoCaptain application, paired with a global navigation satellite system (GNSS) receiver.
- Propulsion Authority: Compatible twin or triple Mercury outboards integrated with Mercury’s Joystick Piloting system, providing multidirectional vector thrust.
Software and AI Framework
Brandon Ferriman, Brunswick’s senior director of program management, classifies AutoCaptain’s current operational parameters as Level 2-plus autonomy on the National Highway Traffic Safety Administration’s six-tiered scale. This means the system is "hands-off," but requires the operator to remain actively stationed at the helm.
The software stack relies on two distinct forms of artificial intelligence:
- Machine Vision: Empowers the onboard processor to "see" and interpret above-the-waterline objects—such as docks, pilings, other watercraft, and floating debris—via the real-time video stream.
- Machine Learning: Enables the system to refine its environmental understanding over time. Unlike static programming, AutoCaptain learns from every marina visit, optimizing its spatial maps and operational efficiency the more it interacts with familiar surroundings.
The User Experience
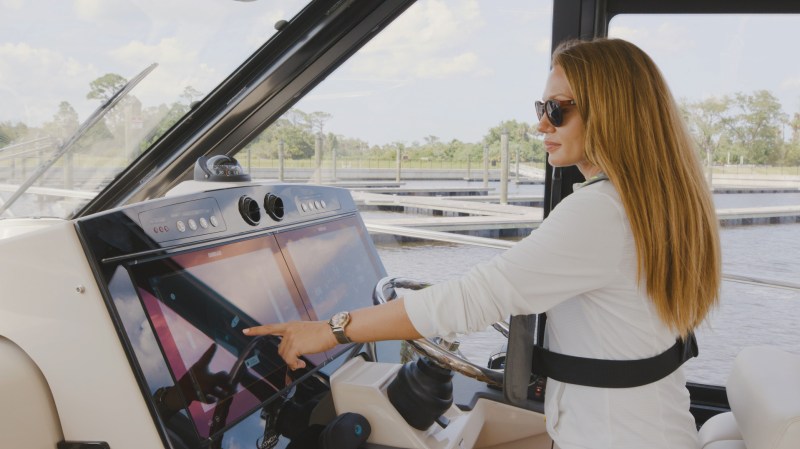
Operating AutoCaptain is designed to be intuitive. The helmsman opens the application on a Simrad display, acknowledges a safety prompt confirming they will remain at the helm, and uses an interactive touchscreen interface to command the vessel’s final parking coordinates (e.g., pulling into a starboard-side slip with the bow facing outward).
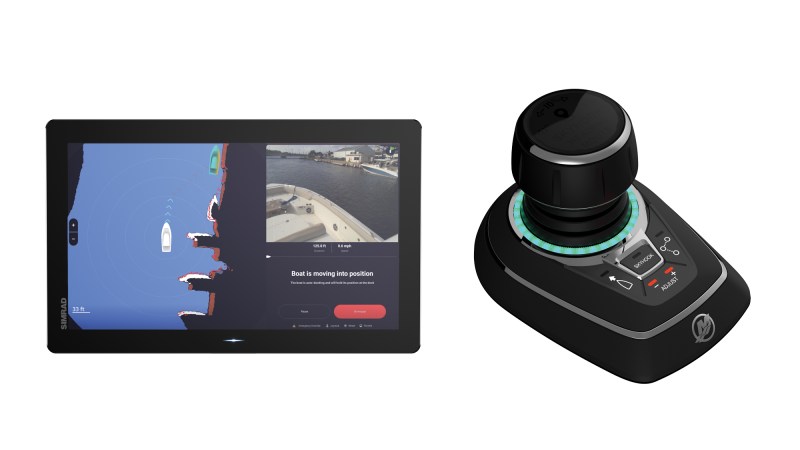
The display splits into three functional panes:
- Port Two-Thirds: A live, camera-generated vector map depicting the immediate surroundings and object placement.
- Starboard One-Third (Top): A live camera feed showing the yacht’s immediate direction of travel.
- Starboard One-Third (Bottom): A critical dialog box featuring prominent "Disengage" and "Pause" buttons.
The Pause button serves as an innovative safety feature—acting as an autonomy-controlled equivalent to Mercury’s Skyhook digital anchor. When engaged, AutoCaptain holds the yacht’s exact position and orientation within a strict one-meter tolerance, buying the skipper time to assess unexpected traffic or distractions.
Official Statements and Industry Insights
The philosophy driving AutoCaptain centers on accessibility, precision, and vertical integration. Leadership from Navico Group and Brunswick Corporation have articulated a clear vision for where the technology stands today and where it is heading.
Jeremiah Clark, Navico Group’s vice president of product management for electronics solutions, emphasizes the deliberate choice to forgo an aftermarket distribution model.
"There’s no aftermarket. There’s no dealer install. The only way to get this is with a new boat," Clark explains, highlighting the stringent calibration requirements necessary for millimeter-accurate stereo-camera alignment and propulsion control.
Detailing the system’s reliance on Mercury’s propulsion technology, Clark notes:
"The joystick system is really what enables the motors to go in different directions, different RPMs, different gears, and using those varying kinds of thrust and vector thrust. You can actually scoot the boat in different directions: sideways, forward, back." Traditional steering wheels and throttles simply cannot deliver the instantaneous, micro-adjusted inputs required for autonomous docking.
Addressing the intelligence built into the platform, Clark adds:
"We’ve taught it what are boats, what are docks, what are obstacles in the water. But over time, the more of those things it sees, the smarter it gets. The system keeps the map, and the more times you visit a place, the better that map gets."
From a safety and operational standpoint, Brandon Ferriman points out the meticulous design choice behind using stereo cameras rather than single-lens setups or radar alone:
"We went with stereo cameras for their accuracy and [ability] to calculate distance and depth of the field of view. That’s how we as humans can see how far away things are." He notes that the cameras require minimal ambient light to function effectively, making dusk and dawn marina returns far less stressful.
Future Outlook: The Next Wave of Marine Automation
While AutoCaptain currently focuses on low-speed, short-range tasks—specifically docking, undocking, and confined spatial positioning—its underlying architecture is inherently expandable.
Software-Driven Evolution
Because AutoCaptain is built within a software-defined framework, future enhancements will be delivered via over-the-air or dealer-applied software updates rather than hardware overhauls. Clark and his team have indicated that future iterations could tap into a broader array of proprietary marine sensors already present on high-end builds. Potential integrations include:
- Forward- and side-scanning sonar systems
- Doppler-enabled marine radar
- Automatic Identification System (AIS) transceivers
By expanding sensor fusion, AutoCaptain’s spatial awareness will stretch beyond visual line-of-sight obstacles, further cementing its reliability in adverse weather or chaotic harbor environments.
Target Audiences and Market Scaling
AutoCaptain serves two distinct demographics within the recreational boating market:
- Beginners: Lowering the barrier to entry by removing the intimidation factor of close-quarters boat handling, thereby encouraging broader participation in boating.
- Experienced Boaters: Serving as a reliable digital co-pilot that mitigates fatigue after long offshore runs or grueling fishing tournaments.
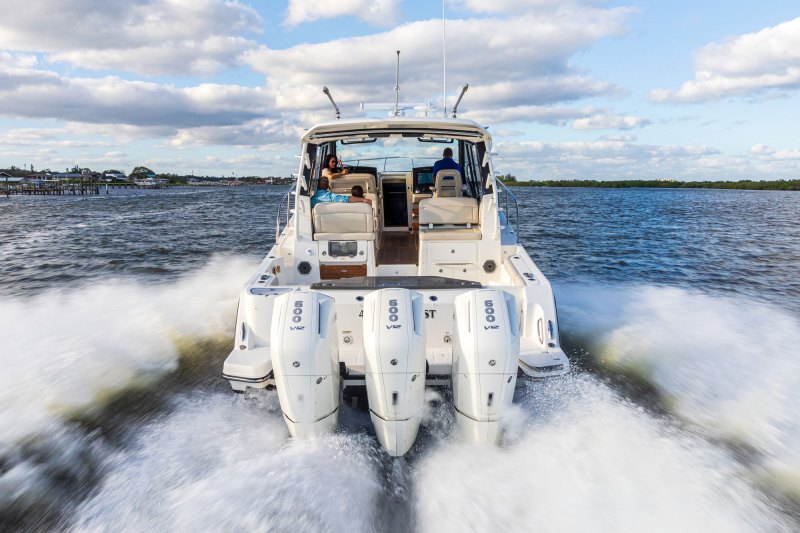
Currently tailored for premium midsize vessels equipped with hardtops and Mercury outboards—such as the Boston Whaler 405 Conquest—the technology’s immediate roadmap remains tied to the Mercury ecosystem. While scaling down to smaller runabouts is limited by the lack of hardtops for camera arrays, and scaling up to superyachts requires navigating diverse propulsion setups, the core autonomy stack holds immense potential for future platform adaptations.
The Walled-Garden Advantage
By keeping design, manufacturing, and servicing within the Brunswick corporate family, AutoCaptain avoids the classic "finger-pointing" dilemma common in marine electronics when multi-brand components fail to communicate. For instance, Mercury’s G3 Service Tool can seamlessly diagnose AutoCaptain software and hardware faults, offering owners peace of mind and streamlined maintenance support.
Conclusion
Simrad’s AutoCaptain does not attempt to replace the joy of open-water seamanship, nor does it claim compliance with complex open-ocean COLREGS (International Regulations for Preventing Collisions at Sea) at high speeds. Instead, it surgically targets the most universally dreaded aspect of boating: the last fifty feet to the slip.
For the modern yacht owner stepping aboard a fully integrated Mercury-powered vessel, AutoCaptain represents a profound evolution in marine technology—transforming docking from a nerve-wracking ordeal of scuffed hulls and shouting crew members into a graceful, automated choreography. And for veterans of the water who remember the white-knuckle days of committee boats and dark, unlit docks, it is nothing short of a revolution.